Sim2Real Twins for Future Mobility – Digital Twins for Autonomous Mobility and Robotics Training
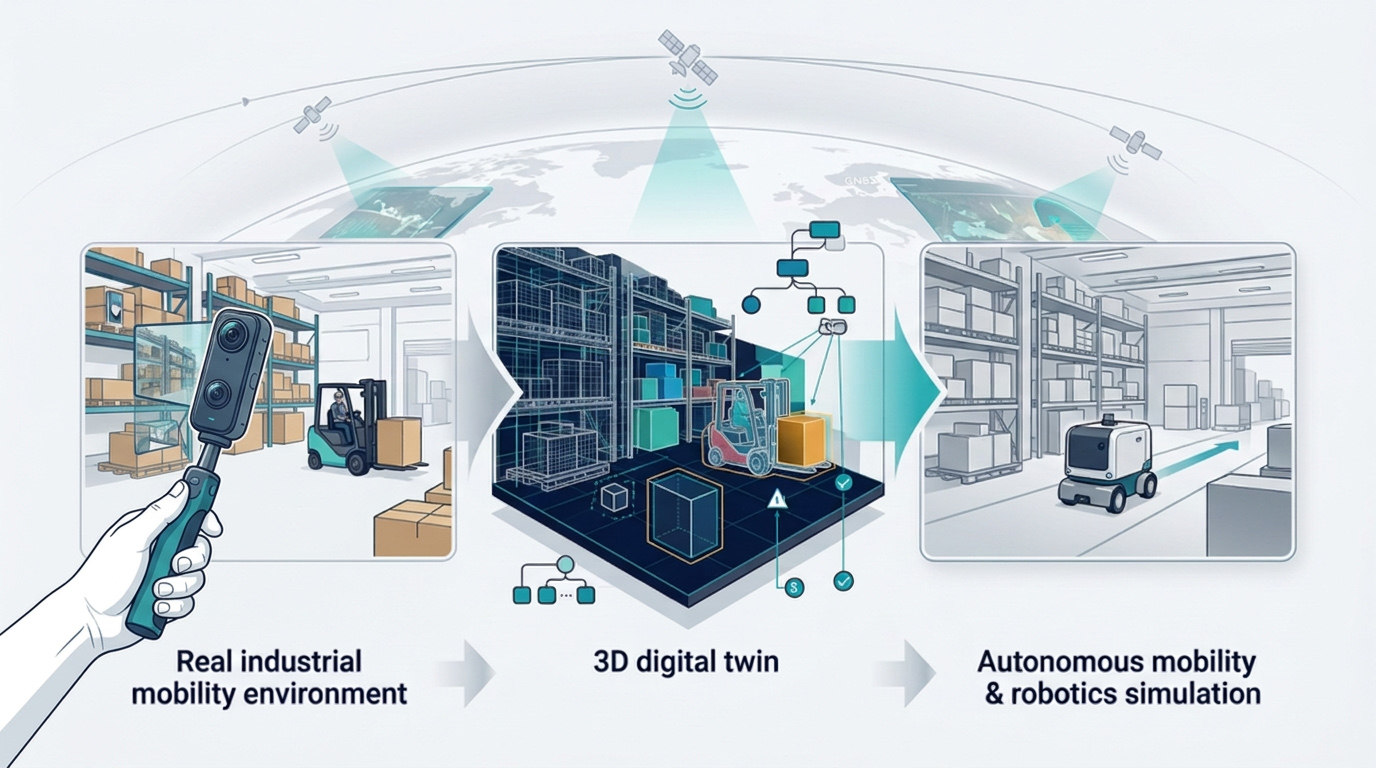
Splatica converts short video clips from the real world into structured, simulation-ready digital twins for autonomous mobility and robotics. Instead of relying on expensive three-dimensional laser scanning (LiDAR) or manually created synthetic environments, Splatica reconstructs real-world spaces using footage from standard cameras and converts these into object-aware, physics-ready OpenUSD scenes that can be used for training, validation and preparation for deployment. The vision is to make the integration of real-world environments into future mobility systems significantly faster and more cost-effective
Benefits:
Lower scene creation costs
Faster adaptation to new facilities or operating environments
Reduced manual engineering effort
More realistic testing conditions for autonomous systems
For robotics and mobility teams, this means shorter deployment cycles, faster Sim2Real transfer and better confidence before real-world rollout.
For operators of warehouses, factories, logistics hubs and similar environments, it reduces the friction involved in introducing automation and makes it easier to update environments as layouts or assets change.